An orientation in MTEX maps crystal coordinates to specimen coordinates. It takes a direction or tensor expressed in the crystal frame and returns the same object expressed in the specimen frame.
A reference frame is the coordinate system in which data are expressed. The crystal frame is the Cartesian frame fixed to a phase’s lattice, while the specimen frame describes the sample in a measurement, rolling, or geological frame.
This page assumes the Miller indices introduced in Crystal Directions and the active rotations from Rotation Operations. Everything below follows from the direction of the coordinate map, including which side a rotation acts on and what happens when the specimen is turned.
from mtex import *
plottingConvention.default('y↑→x')
The Two Ingredients
An orientation combines a rotation with the symmetry, lattice metric, and crystal frame stored by a crystalFrame.
rot = rotation.byEuler(10 * degree, 20 * degree, 30 * degree, 'Bunge')
cs = crystalFrame.load('Al-Aluminum.cif')
cs
crystalFrame (⊙c→a)
  mineral  : Aluminum
  symmetry : m3̅m
  elements : 48
  centering: F
  a, b, c  : 4.05, 4.05, 4.05
The summary identifies aluminium, its point group, lattice parameters, and crystal-frame
alignment. Combining rot and cs gives an orientation.
ori = orientation(rot, cs)
ori
orientation (Aluminum → y↑→x)
  Bunge Euler angles in degree
  phi1  Phi  phi2
    10   20    30
The arrow in the summary reads from the crystal frame on the left to the specimen frame on the right. An orientation is also a rotation, so every rotation operation applies to it.
From Crystal Coordinates to Specimen Coordinates
Take the crystal direction \([100]\).
h = Miller(1, 0, 0, cs, 'uvw')
In a grain with orientation ori, that direction has the following Cartesian components
in the specimen frame.
r = ori * h
r
vector3d (y↑→x)
     x     y      z
  3.12  2.48  0.693
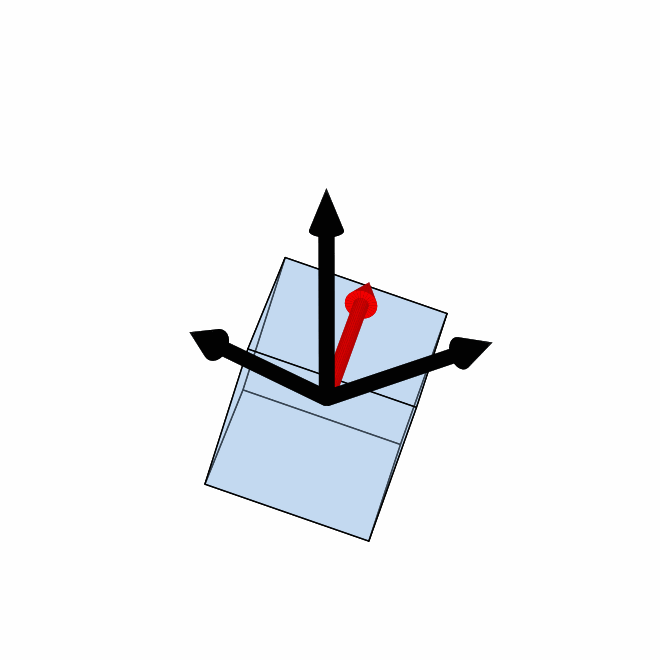
The picture shows the same map. The translucent cube is the crystal where ori places
it. The black arrows are the specimen axes X, Y and Z, and the red arrow is the crystal
direction h expressed in specimen coordinates. The direction is fixed in the lattice;
what the orientation supplies is where the lattice is pointing.
cS = crystalShape.cube(cs)
plot(ori * cS, faceAlpha=0.35, faceColor=[0.6, 0.75, 0.9])
hold(True)
arrow3d(0.75 * normalize(r), faceColor='red')
arrow3d(0.75 * cat(vector3d.X, vector3d.Y, vector3d.Z), faceColor='black')
hold(False)
Other Crystal Objects Transform the Same Way
The same multiplication applies to a stiffness tensor. This example starts with tensor components in the crystal frame.
C = stiffnessTensor([[2, 1, 1, 0, 0, 0],
                     [1, 2, 1, 0, 0, 0],
                     [1, 1, 2, 0, 0, 0],
                     [0, 0, 0, 1, 0, 0],
                     [0, 0, 0, 0, 1, 0],
                     [0, 0, 0, 0, 0, 1]], cs)
C
stiffnessTensor (Aluminum)
  unit: GPa
  rank: 4 (3 × 3 × 3 × 3)
  tensor in Voigt matrix representation
  2  1  1  0  0  0
  1  2  1  0  0  0
  1  1  2  0  0  0
  0  0  0  1  0  0
  0  0  0  0  1  0
  0  0  0  0  0  1
After the coordinate transform, the summary names the specimen frame and displays the transformed components.
Cspecimen = ori * C
Cspecimen
stiffnessTensor (y↑→x)
  unit: GPa
  rank: 4 (3 × 3 × 3 × 3)
  tensor in Voigt matrix representation
   2.4848   0.5709   0.9443  -0.1463  -0.0033  -0.0994
   0.5709   2.5851    0.844  -0.1116   0.0399   0.0558
   0.9443    0.844   2.2117   0.2579  -0.0367   0.0436
  -0.1463  -0.1116   0.2579    0.844   0.0436   0.0399
  -0.0033   0.0399  -0.0367   0.0436   0.9443  -0.1463
  -0.0994   0.0558   0.0436   0.0399  -0.1463   0.5709
Everything defined in the crystal frame travels in the same direction:
- crystal directions
- tensors
- slip systems
- twinning systems
- dislocation systems
- crystal shapes
And Back Again
The inverse orientation maps specimen coordinates to crystal coordinates. Applying it to
r therefore returns the direction we started from.
hBack = inv(ori) * r
hBack
vector3d (Aluminum)
        h  k  l
  16.3991  0  0
The displayed coefficients do not resemble \([100]\) yet. A Miller made from a specimen
direction displays as \((hkl)\) unless told otherwise, while the original \([100]\)
direction has the aluminium lattice-vector length of 4.04958 Angstrom. Selecting
lattice-direction notation and rounding recovers the original indices.
hBack.dispStyle = 'uvw'
hRounded = round(hBack)
hRounded
vector3d (Aluminum)
  u  v  w
  1  0  0
Much of the literature defines an orientation in the opposite direction, from specimen
to crystal coordinates. That is what MTEX calls inv(ori). Both conventions are in use,
and reading Euler angles with the wrong one inverts every orientation in the data. See
MTEX vs. Bunge Convention for the practical consequences.
Turning the Specimen
Putting the sample on the stage in another position actively turns the crystal relative to the fixed measurement frame. A rotation expressed in specimen coordinates therefore multiplies every orientation from the left.
rotSpecimen = rotation.byAxisAngle(vector3d.X, 60 * degree)
oriNew = rotSpecimen * ori
Every crystal direction moves with the specimen. Going through the new orientation and turning the old specimen direction must agree.
leftConsistency = angle(oriNew * h, rotSpecimen * r) / degree
leftConsistency
2.1943e-15
The residual is numerically zero. The same rotation written on the right is interpreted
in crystal coordinates: it turns the direction inside the lattice before ori maps that
direction into the specimen frame.
rightDifference = angle(ori * (rotSpecimen * h), oriNew * h) / degree
rightDifference
37.1140
The nonzero result confirms that left and right multiplication describe different operations. The rotation on the right acts first, just as in ordinary matrix multiplication.
Crystal Symmetry Also Acts from the Right
Right multiplication has a second, symmetry-aware meaning. A point-group operation changes the crystal-frame representative but not the physical crystal setting. symmetrise lists those equivalent descriptions.
equivalentCount = len(ori.symmetrise())
equivalentCount
24
The count is 24, the number of proper operations in aluminium’s m-3m point group; only
those are rigid rotations and only those give another setting of the same crystal. The
24 improper operations remain symmetries of the lattice and are relevant when opposite
plane normals are treated as equivalent.
A symmetry-aware orientation comparison regards all 24 descriptions as equivalent, so
their largest angular difference from ori vanishes.
symmetryResidual = max(angle(ori.symmetrise(), ori)) / degree
symmetryResidual
0
Rotating Is Not Changing Frame
The stage rotation above moves the physical object in a fixed frame. A frame change instead re-expresses the same physical object in another reference frame and leaves the object untouched. Use transformReferenceFrame when crystal data use a different Cartesian crystal frame. Orientations also depend on how the Cartesian crystal frame \(\vec x\), \(\vec y\), \(\vec z\) is inscribed into the crystal axes \(\vec a\), \(\vec b\), \(\vec c\).
A plotting convention only states how a reference frame is laid out on screen. Changing it does not rotate the specimen or re-express the data. The Crystal Reference System develops both distinctions for crystal axes.
The Maths Behind the Multiplication Order
Let \(\mathbf{G}\) be the matrix of ori, and let \(\mathbf{h}\) and \(\mathbf{r}\) contain
the crystal and specimen components of one direction. Then
The transpose appears because a rotation matrix is orthogonal, so \(\mathbf{G}^{-1}=\mathbf{G}^{\mathrm{T}}\). A specimen rotation \(\mathbf{Q}\) gives \(\mathbf{QG}\), while a crystal-frame rotation \(\mathbf{P}\) gives \(\mathbf{GP}\). This is the matrix form of the two multiplication examples above.
The same rule determines the order of a misorientation product. See Misorientations.
References
- H.-J. Bunge, Texture Analysis in Materials Science: Mathematical Methods, Butterworths, English ed., 1982, establishes the Euler-angle and orientation conventions used in texture analysis.
- A. Morawiec, Orientations and Rotations: Computations in Crystallographic Textures, Springer, 2004, develops coordinate maps, symmetry, and the geometry of orientation space.
- D. Rowenhorst et al., Consistent representations of and conversions between 3D rotations, Modelling and Simulation in Materials Science and Engineering 23, 083501, 2015, compares active and passive conventions and gives reproducible conversion rules.
- ISO 24173:2024, Microbeam analysis – Guidelines for orientation measurement using electron backscatter diffraction, gives current guidance for reproducible EBSD orientation measurements.
Next
Symmetry develops the equivalent rotations that an orientation represents. Pole Figures then draws the specimen directions computed here, while Inverse Pole Figures asks the inverse question.
Citing this page.
This page is part of the documentation of
MTEX, a free and open
source MATLAB toolbox for analyzing and modeling crystallographic textures.
It was written by The MTEX Developers and is published at
https://mtex-toolbox.github.io/DefinitionAsCoordinateTransform_py.html.
If you use MTEX, or reuse text or figures from this page, in your research,
please cite
F. Bachmann, R. Hielscher, H. Schaeben: Texture Analysis with MTEX - Free and Open Source Software Toolbox, Solid State Phenomena 160 (2010), 63-68. 10.4028/www.scientific.net/SSP.160.63
BibTeX
@article{bachmann2010mtex,
  author  = {F. Bachmann and R. Hielscher and H. Schaeben},
  title   = {Texture Analysis with MTEX - Free and Open Source Software Toolbox},
  journal = {Solid State Phenomena},
  volume  = {160},
  pages   = {63-68},
  year    = {2010},
  doi     = {10.4028/www.scientific.net/SSP.160.63},
  url     = {https://doi.org/10.4028/www.scientific.net/SSP.160.63}
}
Other papers describing specific MTEX methods are listed under Publications — please cite the one that best fits your application. The MTEX source code is licensed under the GNU General Public License v2.0; the text and figures of this documentation are licensed under CC BY 4.0, which permits reuse — including by automated systems — provided The MTEX Developers and this page are credited.