A spatial transform maps positions in one coordinate system to positions in another. It can describe the distortion between an EBSD map and an SEM image, stage drift during a scan, or the foreshortening of a tilted surface.
This is different from a reference frame, the coordinate system in which specimen or crystal data are expressed. A spatial transform moves map positions but does not correct the orientations stored at those positions. Use Reference Frame Alignment when the map coordinates and Euler angles do not refer to the same specimen frame.
A function handle can move positions too. A spatialTransform also composes, inverts, displays itself, fits measured point pairs, and can be stored for another data set. Maps and Images explains how two images first come to share a specimen coordinate system and array layout.
plottingConvention.default('y↑→x');
mtexdata twins silent
Direction Is the Contract
One rule fixes everything else: T maps a position in coordinate system A to the position of the same physical point in coordinate system B.
The product T2 * T1 reads in matrix order, so T1 is applied first. Filling a regular output grid uses inv(T) rather than T. For each target pixel, the resampler has to ask where it came from, not where it goes.
Spatial transforms are two dimensional. They act on \(x\) and \(y\) and leave \(z\) unchanged.
T = spatialTransformRigid(vector3d(5,-2,0))T = spatialTransformRigid
model stage parameters
rigid · move (5, -2)Apply a transform to positions with *, or call eval explicitly.
pos = ebsd.pos(1,1:3);
posMoved = T * pos;

[pos.x(:), posMoved.x(:)]
ans =
0 5.0000
0.3000 5.3000
0.6000 5.6000Choose the Smallest Model That Describes the Distortion
Each class represents a different amount and pattern of spatial freedom. The names are historical, so read their meanings rather than guessing from them:
-
spatialTransformIdmeans that nothing separates the two coordinate systems. -
spatialTransformRigidis one translation, the same everywhere. It does not include a rotation. -
spatialTransformShiftis a full 2D affine map: translation, rotation, scale, and shear in one homogeneous matrix. -
spatialTransformProjectiveis a homography. It keeps lines straight, but parallel lines need not remain parallel, as in a perspective view of a tilted plane. -
spatialTransformTiltis the staged model used to recover specimen tilt from repeatedly correlated image pairs. -
spatialTransformPolydescribes a displacement that varies polynomially across the coordinate system. -
spatialTransformDriftvaries only along the slow scan direction. It models rolling-shutter-like scan drift rather than an arbitrary smooth field. -
spatialTransformFieldstores measured displacements and interpolates between their positions without imposing a parametric model. -
spatialTransformHandlewraps a function handle when none of the fitted models applies.
Start with the least flexible model that has a physical reason to be present. A flexible model can follow noise and may extrapolate badly beyond the point pairs. Correspondences should span the area that will be transformed, and residuals should also be checked at withheld landmarks.
Differently modelled hops can be stored in one heterogeneous array rather than a cell array. Such an array is an ordered sequence of hops, not a set of alternatives. It is primarily a container: combine the required hops or process them one at a time before calling methods such as inv on them.
[spatialTransformRigid(vector3d(1,0,0)), ...
  spatialTransformPoly(zeros(3,2),1)]
ans = spatialTransform
size: 1 × 2
model stage parameters
1 rigid · move (1, 0)
2 poly11 · |c| = 0Fit a Transform From Two Point Sets
A transform is usually measured rather than written down. Locate the same features in both coordinate systems, then ask the chosen class for the member of its family that maps the first set onto the second. The two sets must use the same length unit and point order.
The geometric minimum is not enough for a reliable fit. An affine needs at least three non-collinear pairs, a homography at least four well-spread pairs, and a degree-two polynomial at least six. More pairs let a fit expose noise and mismatches.
For an example with a known answer, apply a projective distortion to map positions and fit the homography back from the resulting pairs.
T0 = spatialTransformProjective([1 0.02 3; -0.01 1.05 -2; 1e-4 2e-4 1]);

posA = ebsd.pos(1:50:end);
posB = T0 * posA;

T = spatialTransformProjective.fit(posA,posB)
T = spatialTransformProjective
model stage parameters
projective · perspective (0.0001, 0.0002)The maximum error is at rounding level.
max(norm(T*posA - posB))ans =
2.8422e-14Real correspondences are not this clean. Projective and polynomial fits use Tukey bisquare reweighting, so points that disagree with the consensus lose influence. Here every tenth target point is moved somewhere else.
posBad = posB;
posBad(1:10:end) = posBad(1:10:end) + vector3d(30,-40,0);

TBad = spatialTransformProjective.fit(posA,posBad);

max(norm(TBad*posA - posB))
ans =
2.1335e-14Other classes match their physical model: a rigid fit takes a weighted mean displacement, an affine uses weighted least squares, drift uses a median displacement per scan line, and a field keeps the samples exactly.
Where a confidence per pair is available, pass it with 'weights' instead of asking the fit to infer every bad match. Cross-correlation supplies such weights; see xcfShift.
Declare a Model With + and Compose Fitted Transforms With *
There are two ways to put transforms together, and they are not the same operation.
* composes fitted transforms and simplifies where it can. It decides by value, so an operand that reports isid disappears. An unfitted prototype has zero coefficients and therefore reports itself as the identity. In the product below, the shift silently disappears and only the drift remains.
spatialTransformShift * spatialTransformDriftans = spatialTransformDrift
model stage parameters
drift · (no knots)
+ declares a model. It reads left to right in the order the stages are applied and keeps both. Only a literal spatialTransformId is dropped, because that class means that nothing separates the two coordinate systems.
spatialTransformShift + spatialTransformDriftans = spatialTransformComposite
model stage parameters
shift-drift shift scale 1 × 1, rotate 0°, shear 0°, move (0, 0)
drift (no knots)Use + for a distortion model that is about to be fitted, and * for transforms whose coefficients are already known. Here + chains maps; it does not add displacements as + on a vector3d would.
Both operations flatten composites rather than nesting them, and their application order is consistent.
R = spatialTransformRigid(vector3d(1,-2,0));
S = spatialTransformShift([1 0.1 0; 0 1 0; 0 0 1]);

max(norm((R + S)*posA - S*(R*posA)))
ans =
0Inverting
Rigid, affine, projective, and degree-one polynomial transforms have exact inverses. Their inv returns another closed-form transform.
inv(T)ans = spatialTransformProjective
model stage parameters
projective · perspective (-0.000102, -0.000189)A degree-two polynomial, drift spline, or scattered field has no general closed-form inverse. Its inverse is a spatialTransformInverse, which solves for each source position iteratively.
P = spatialTransformPoly.fit(posA,posB,'degree',2);

Pinv = inv(P)
Pinv = spatialTransformInverse
model stage parameters
inv-poly22 · |c| = 3.606The round trip returns the sampled positions to rounding level.
max(norm(eval(Pinv,P*posA) - posA))ans =
6.5286e-11Iteration converges while the displacement gradient remains below one in the queried region. A field that folds has no unique inverse. Asking far outside the region used for fitting can also fail, and the inverse reports either failure rather than returning a wrong position.
Collapse a Chain at Chosen Positions
Evaluating every stage repeatedly is wasted work when the chain will be applied to many pixels. discretize samples a chain at chosen positions and returns one spatialTransformField.
F = discretize(R + S, posA)F = spatialTransformField
model stage parameters
field · 458 points, |u| <= 5.274The field agrees with the chain at the sample positions. Between them it uses scattered interpolation, so the sampling density controls fidelity.
max(norm(F*posA - (R + S)*posA))ans =
0Apply a Transform to an EBSD Map
EBSD/transform moves every pixel and carries its unit cell with it. Orientations, phase labels, and all per-pixel properties remain untouched. A spatial transform therefore corrects map geometry, not an orientation or specimen-reference-frame error.
Carrying the unit cell is exact for an affine transform. For a nonlinear transform, one global unit cell can only represent the local transform at the map centre. The second argument may be a spatialTransform or a plain function handle.
ebsdT = transform(ebsd,S);

plot(ebsd,ebsd.bc,'micronbar','off','layout',[1,2]), mtexColorMap gray
title('as imported')
nextAxis
plot(ebsdT,ebsdT.bc,'micronbar','off'), mtexColorMap gray
title('sheared')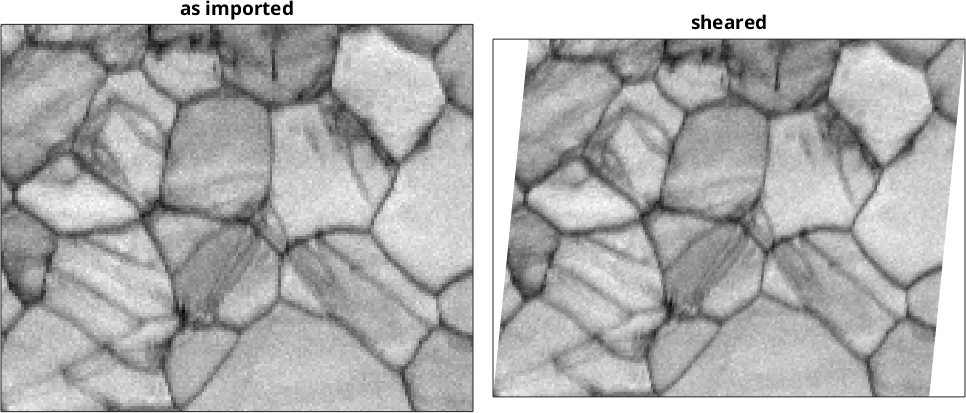
The right map has a sheared footprint, while the band-contrast values keep the same spatial order. The transform changed geometry, not the property.
grain2d/transform applies the same idea to a grain map by moving its vertices. This lets a map and grains reconstructed from it pass through the same known distortion.
Because this affine transform has an exact inverse, the original pixel positions are recovered.
ebsdBack = transform(ebsdT,inv(S));

max(norm(ebsdBack.pos - ebsd.pos),[],'all')
ans =
7.1054e-15Where the Point Pairs Come From
Nothing above measured a distortion: posA and posB were manufactured. In practice, pairs often come from correlating two images of the same area. xcfShift divides their shared region into tiles, phase correlates each tile with its counterpart, and returns a displacement and correlation-peak height for every tile.
The images must first share a pixel grid, and their stored order must refer to the same specimen directions. With mapImage inputs, xcfShift returns positions and displacements in specimen units rather than pixels.
The peak height is a fit weight, not a registration diagnostic. A tile on featureless background must not receive an equal vote:
[u,peak,pos] = xcfShift(imRef,imTest);
T = spatialTransformShift.fit(pos, pos + u, 'weights', peak);
Maps and Images prepares that common geometry. The TrueEBSD example runs the complete chain on real data and checks the residual after correction.
References
- G. Nolze, Image distortions in SEM and their influences on EBSD measurements, Ultramicroscopy 107, 172--183, 2007, relates specimen tilt, scan geometry, and orientation error.
- V. S. Tong and T. B. Britton, TrueEBSD: Correcting spatial distortions in electron backscatter diffraction maps, Ultramicroscopy 221, 113130, 2021, develops the physically staged correction used by TrueEBSD.
- M. Guizar-Sicairos, S. T. Thurman, and J. R. Fienup, Efficient subpixel image registration algorithms, Optics Letters 33, 156--158, 2008, gives the Fourier-domain subpixel registration method used by
xcfShift. - B. Zitova and J. Flusser, Image registration methods: a survey, Image and Vision Computing 21, 977--1000, 2003, organizes registration into feature detection, matching, transform choice, and resampling.
- R. Hartley and A. Zisserman, Multiple View Geometry in Computer Vision, second edition, Cambridge University Press, 2004, develops homogeneous coordinates, homographies, and the direct linear transform.
Next
Continue with TrueEBSD Distortion Correction to fit a sequence of physical distortion models to real EBSD and SEM images. See Square and Hex Grids when the transformed map must recover or preserve its lattice structure.
Correct the geometry before grain reconstruction when grain shape, boundary length, or correlative overlap matters. If grains already exist, transform both the map and its grain map.
Citing this page.
This page is part of the documentation of
MTEX, a free and open
source MATLAB toolbox for analyzing and modeling crystallographic textures.
It was written by The MTEX Developers and is published at
https://mtex-toolbox.github.io/EBSDSpatialTransform.html.
If you use MTEX, or reuse text or figures from this page, in your research,
please cite
F. Bachmann, R. Hielscher, H. Schaeben: Texture Analysis with MTEX - Free and Open Source Software Toolbox, Solid State Phenomena 160 (2010), 63-68. 10.4028/www.scientific.net/SSP.160.63
BibTeX
@article{bachmann2010mtex,
  author  = {F. Bachmann and R. Hielscher and H. Schaeben},
  title   = {Texture Analysis with MTEX - Free and Open Source Software Toolbox},
  journal = {Solid State Phenomena},
  volume  = {160},
  pages   = {63-68},
  year    = {2010},
  doi     = {10.4028/www.scientific.net/SSP.160.63},
  url     = {https://doi.org/10.4028/www.scientific.net/SSP.160.63}
}
Other papers describing specific MTEX methods are listed under Publications — please cite the one that best fits your application. The MTEX source code is licensed under the GNU General Public License v2.0; the text and figures of this documentation are licensed under CC BY 4.0, which permits reuse — including by automated systems — provided The MTEX Developers and this page are credited.